Frontier Systems & Research Builds · Expert
Liquid-Slosh Balancing Robot
Mobile platform carrying an open half-full liquid payload without spilling. Mobile platform carrying an open half-full liquid payload without spilling.
Components
- ESP32 or Teensy
- IMU
- load/spill sensor
- geared drive
Build steps
- Inventory the board, actuators, sensors, and power rails listed for F01.
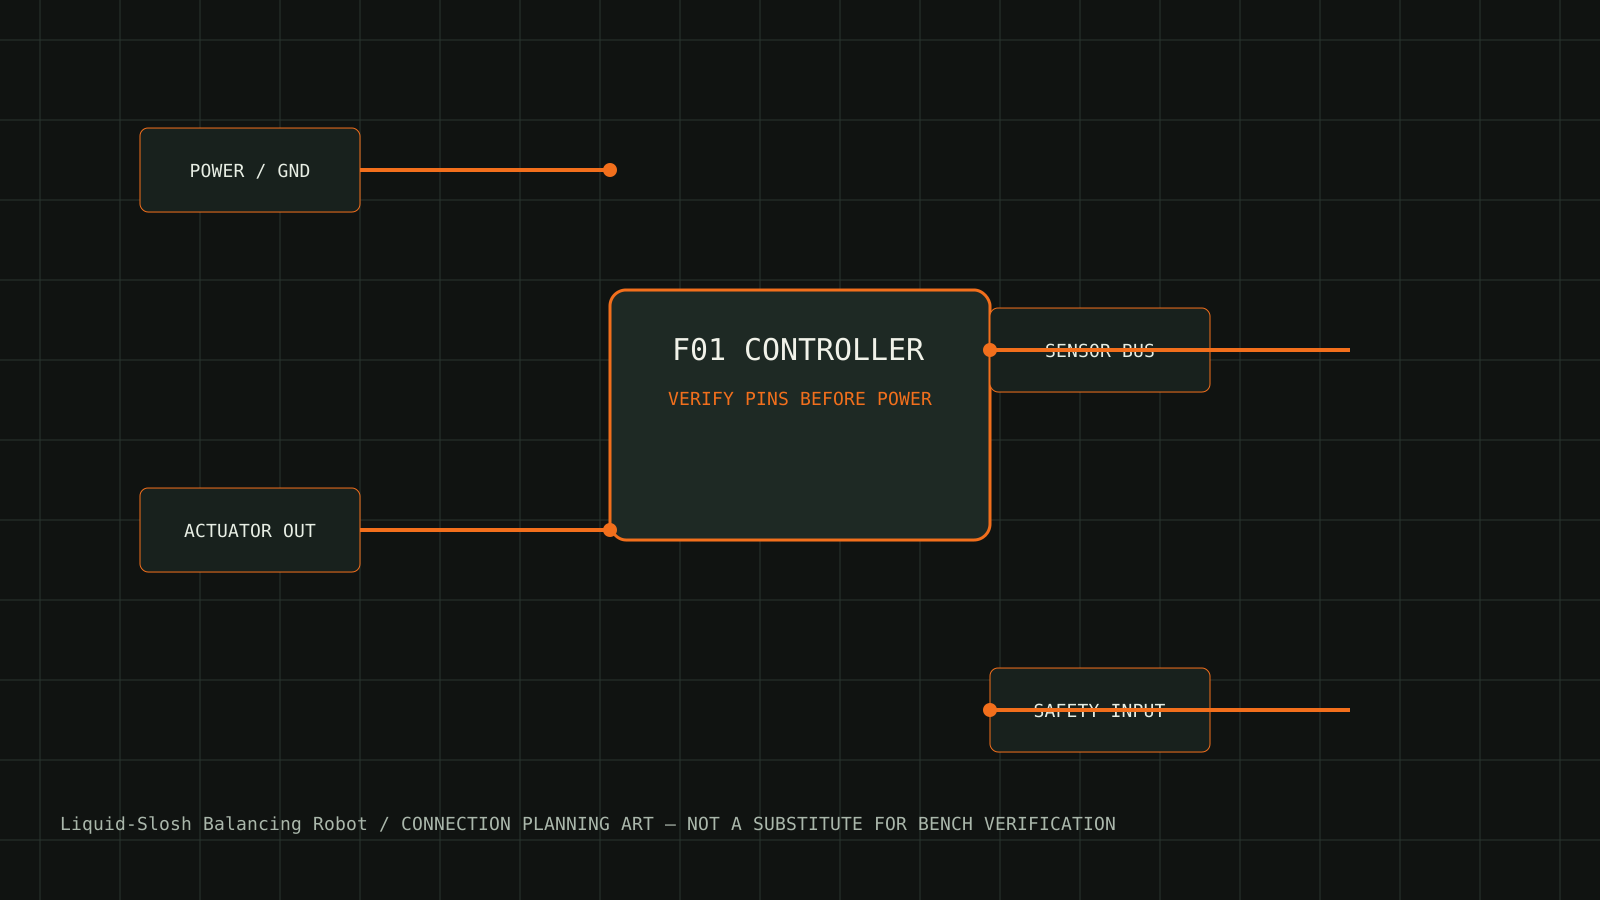
- Build and inspect the low-voltage wiring against the supplied connection diagram before connecting actuators.
- Flash the firmware, run the startup self-check, and record the printed board and firmware version.
- Calibrate the sensors and limits, then run the acceptance tests at the lowest safe energy level.
Test and expected result
Characterize slosh, baffles, center-of-mass shift, IMU filtering, and spill threshold.
Safety and limits
No-spill threshold must be measured; use a tether and low-speed first tests.
Download connection diagram SVG