Frontier Systems & Research Builds · Expert
Robotic Knot-Tying Station
Dual-arm system that identifies and loosens climbing-rope knots. Dual-arm system that identifies and loosens climbing-rope knots.
Components
- Dual-arm controller
- force sensors
- camera or fiducial tracking
Build steps
- Inventory the board, actuators, sensors, and power rails listed for F02.
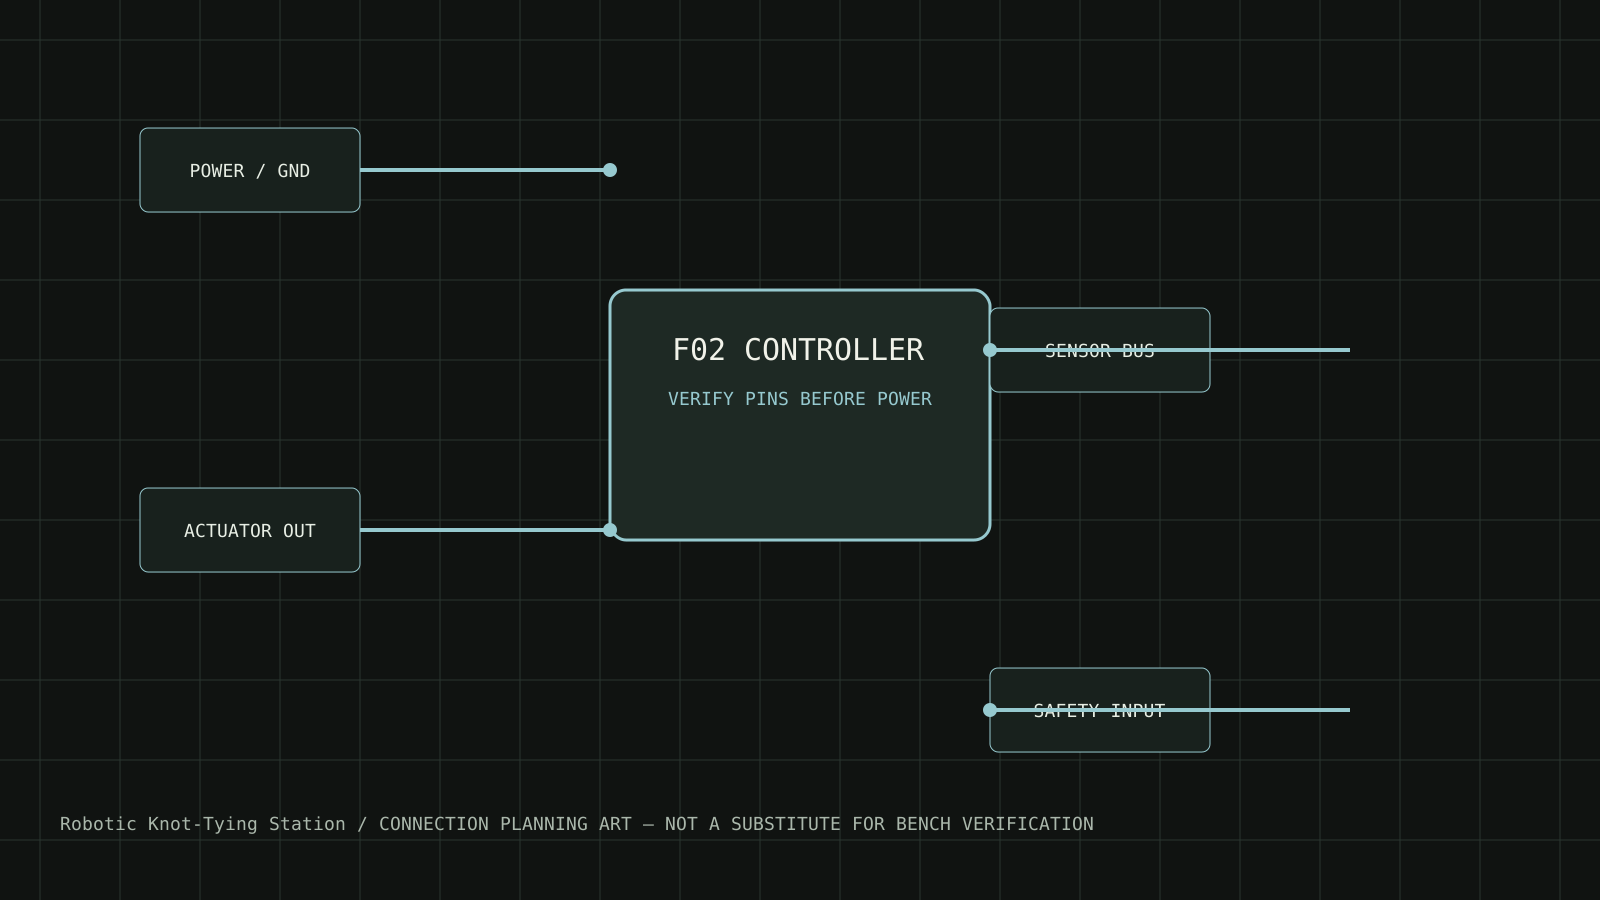
- Build and inspect the low-voltage wiring against the supplied connection diagram before connecting actuators.
- Flash the firmware, run the startup self-check, and record the printed board and firmware version.
- Calibrate the sensors and limits, then run the acceptance tests at the lowest safe energy level.
Test and expected result
Collect rope poses, calibrate force feedback, and validate release force across knot types.
Safety and limits
Use soft test rope and low force; never test around hands or body.
Download connection diagram SVG