Hybrid Cross-Domain Builds · Advanced
Autonomous Greenhouse Rover
Mobile robot combining navigation, plant sensing, and targeted inspection. Mobile robot combining navigation, plant sensing, and targeted inspection.
Components
- MCU/ROS-lite rover
- plant sensors
- local telemetry
Build steps
- Inventory the board, actuators, sensors, and power rails listed for H01.
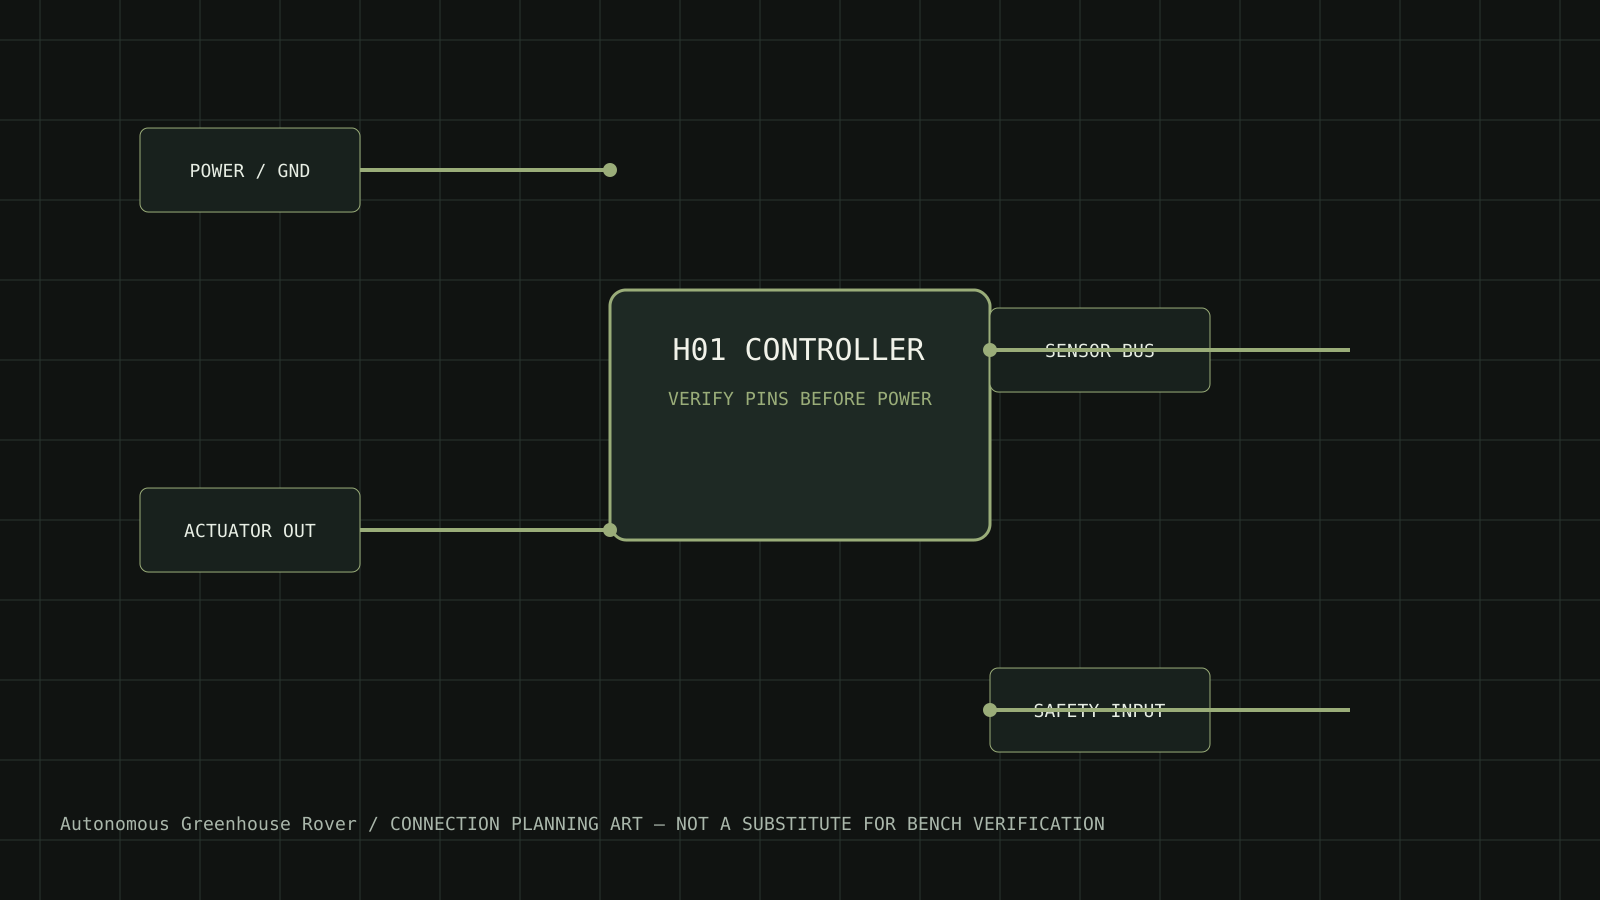
- Build and inspect the low-voltage wiring against the supplied connection diagram before connecting actuators.
- Flash the firmware, run the startup self-check, and record the printed board and firmware version.
- Calibrate the sensors and limits, then run the acceptance tests at the lowest safe energy level.
Test and expected result
Test navigation separately, then add sensing; record plant-safe operating limits.
Safety and limits
Protect plants and use a low-speed indoor route.
Download connection diagram SVG