Hybrid Cross-Domain Builds · Advanced
Gesture-Controlled Robotic Arm
Local gesture interface commanding a bounded arm pose library. Local gesture interface commanding a bounded arm pose library.
Components
- MCU/PC gesture input + bounded arm pose controller
- Regulated low-voltage bench supply
- Emergency stop or safe fallback input
Build steps
- Inventory the board, actuators, sensors, and power rails listed for H02.
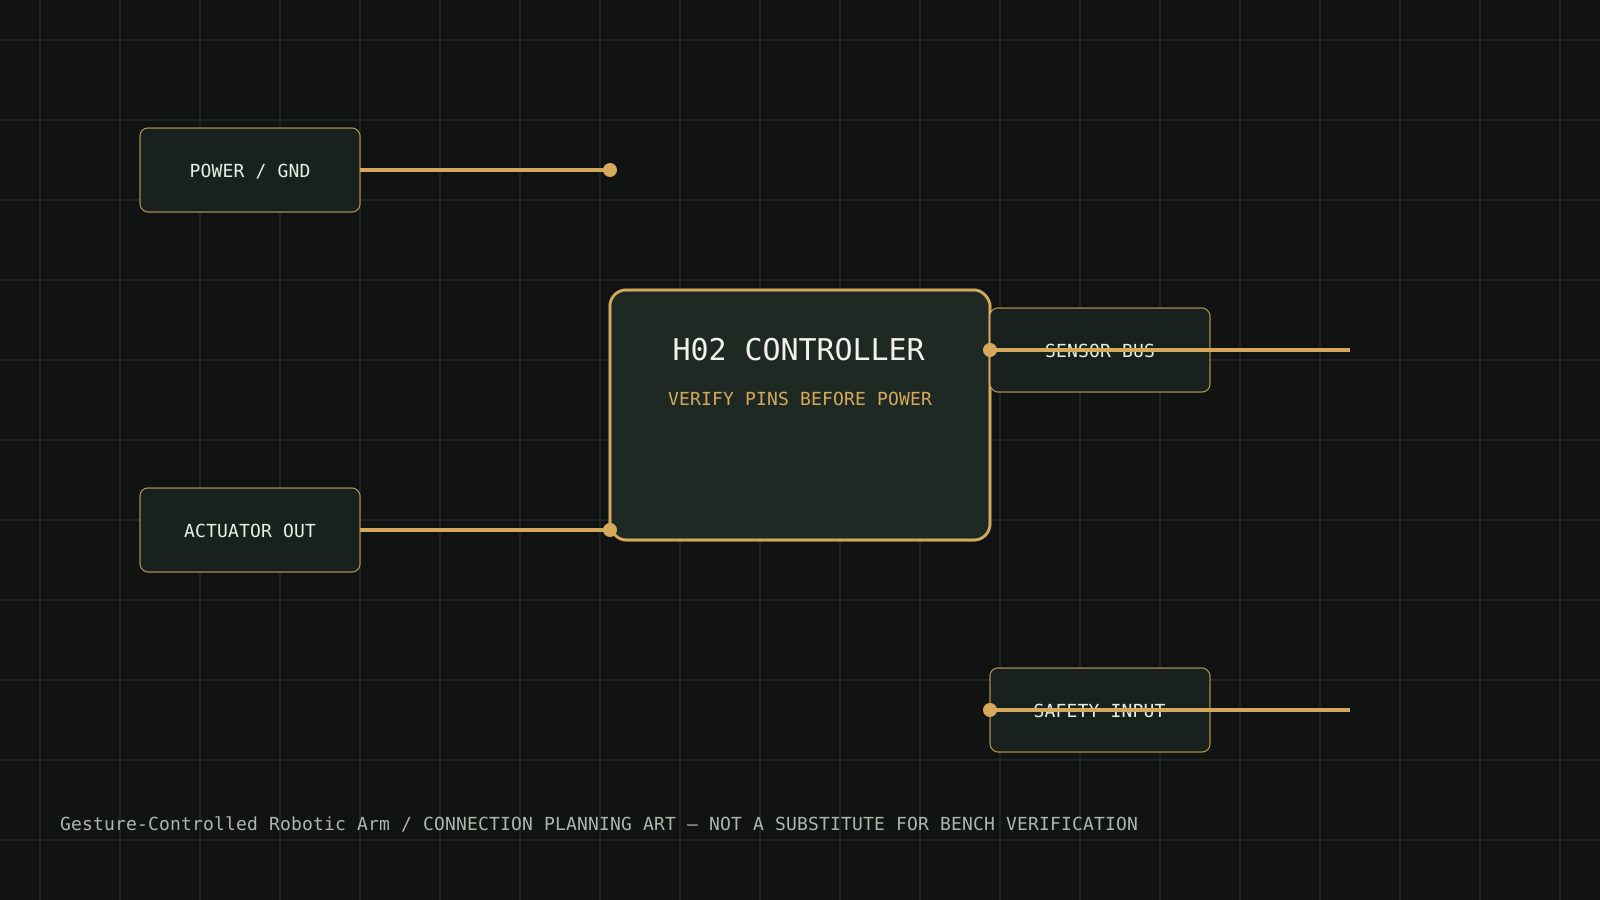
- Build and inspect the low-voltage wiring against the supplied connection diagram before connecting actuators.
- Flash the firmware, run the startup self-check, and record the printed board and firmware version.
- Calibrate the sensors and limits, then run the acceptance tests at the lowest safe energy level.
Test and expected result
Validate recognition confidence, safe fallback, joint limits, and manual override.
Safety and limits
No unconstrained gesture-to-motion mapping.
Download connection diagram SVG