Industrial & Biomedical Automation · Intermediate
Soft-Grip Servo Hand
Low-cost haptic mechanism designed around gentle contact with human-safe test objects. Low-cost haptic mechanism designed around gentle contact with human-safe test objects.
Components
- MCU
- servo hand
- force/current sensing
Build steps
- Inventory the board, actuators, sensors, and power rails listed for I01.
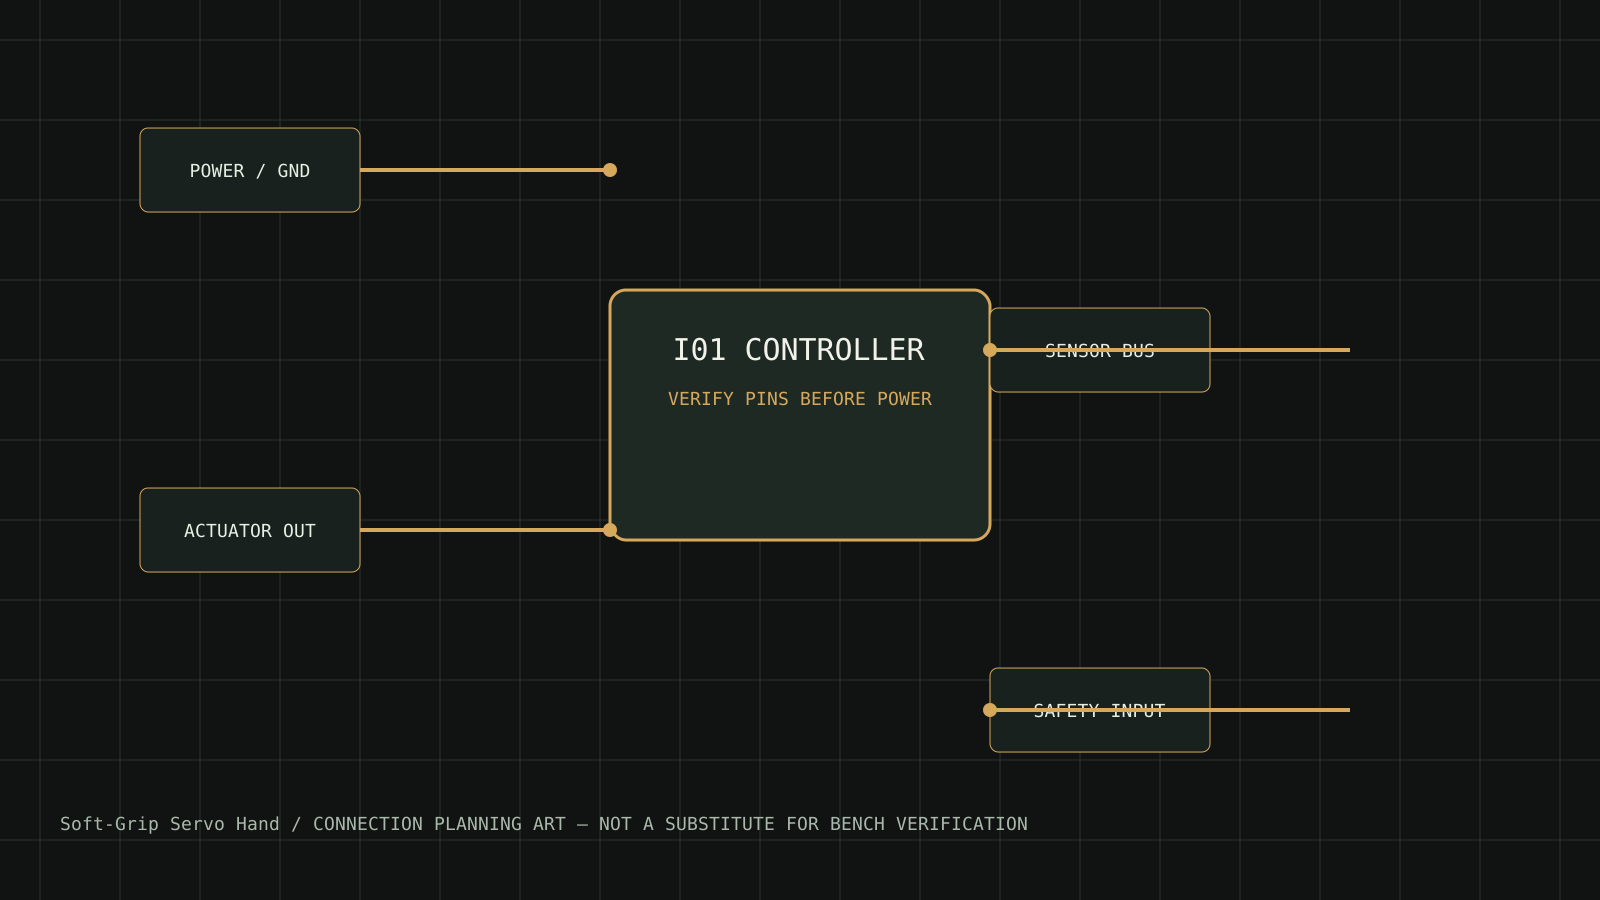
- Build and inspect the low-voltage wiring against the supplied connection diagram before connecting actuators.
- Flash the firmware, run the startup self-check, and record the printed board and firmware version.
- Calibrate the sensors and limits, then run the acceptance tests at the lowest safe energy level.
Test and expected result
Force limit, repeatability, pinch-point guarding, and release on power loss.
Safety and limits
Non-clinical prototype; never attach to a person.
Download connection diagram SVG