Advanced Robotics & Kinematics · Advanced
Self-balancing Rover
Two-wheel inverted-pendulum rover using an IMU and closed-loop motor control. Two-wheel inverted-pendulum rover using an IMU and closed-loop motor control.
Components
- ESP32/Arduino
- IMU
- motor driver
- encoders
Build steps
- Inventory the board, actuators, sensors, and power rails listed for R02.
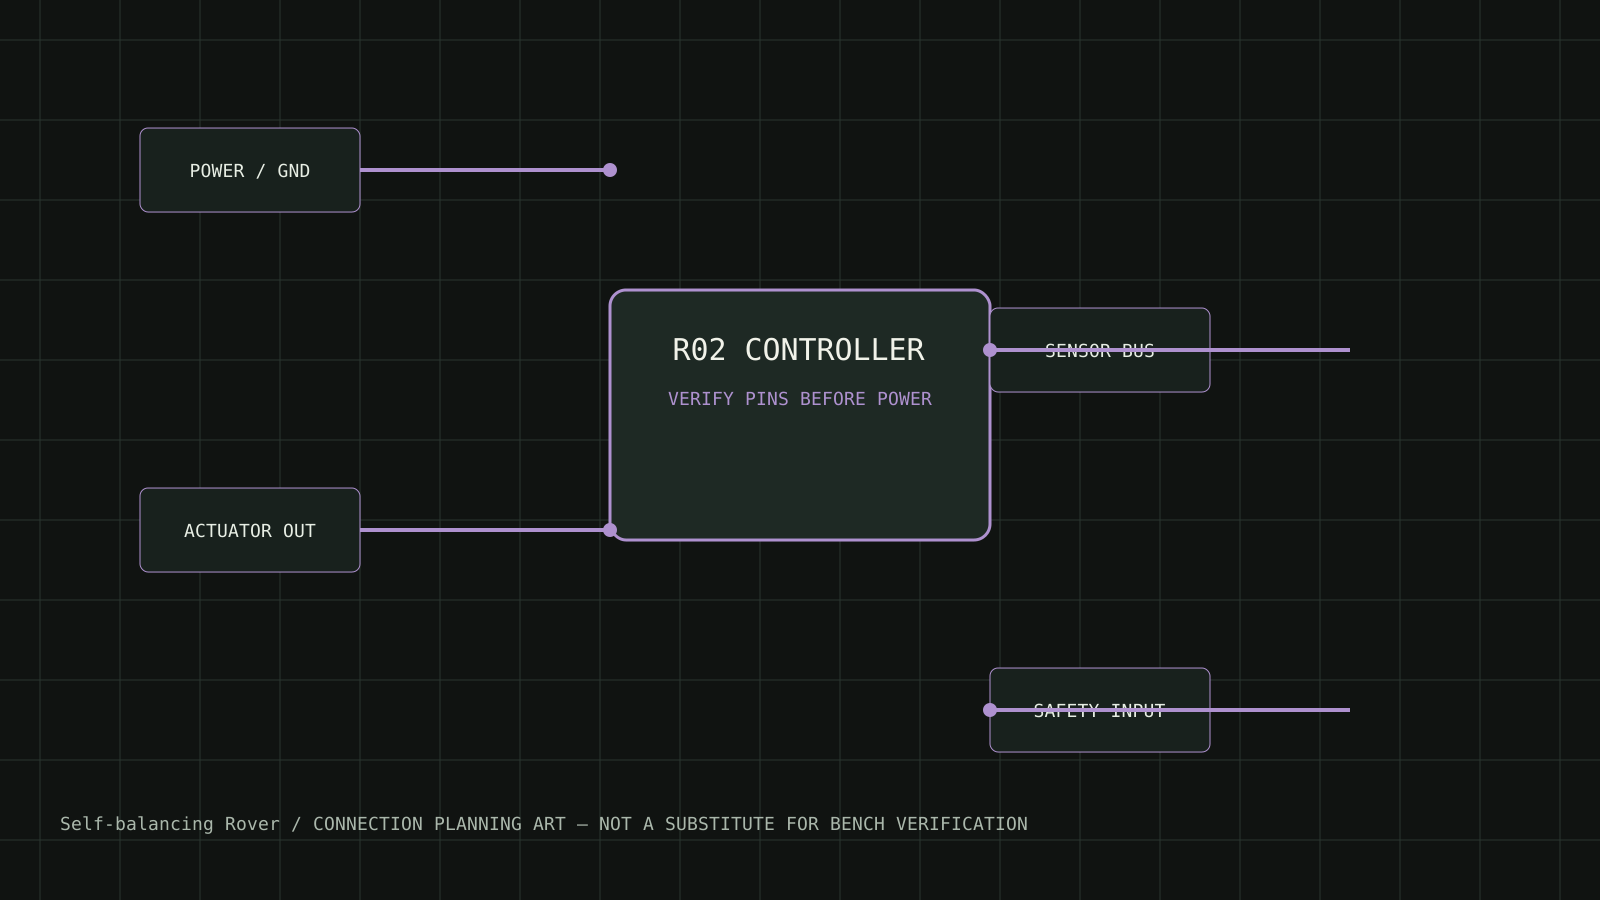
- Build and inspect the low-voltage wiring against the supplied connection diagram before connecting actuators.
- Flash the firmware, run the startup self-check, and record the printed board and firmware version.
- Calibrate the sensors and limits, then run the acceptance tests at the lowest safe energy level.
Test and expected result
Tune from low motor power; measure recovery time and steady-state tilt after a gentle push.
Safety and limits
Begin with wheels raised and use a physical kill switch.
Download connection diagram SVG