Advanced Robotics & Kinematics · Advanced
4-DOF Robotic Arm
Four servo joints reproducing repeatable poses and a safe neutral position. Four servo joints reproducing repeatable poses and a safe neutral position.
Components
- Arduino
- 4 servo joints
- optional gripper
Build steps
- Inventory the board, actuators, sensors, and power rails listed for R03.
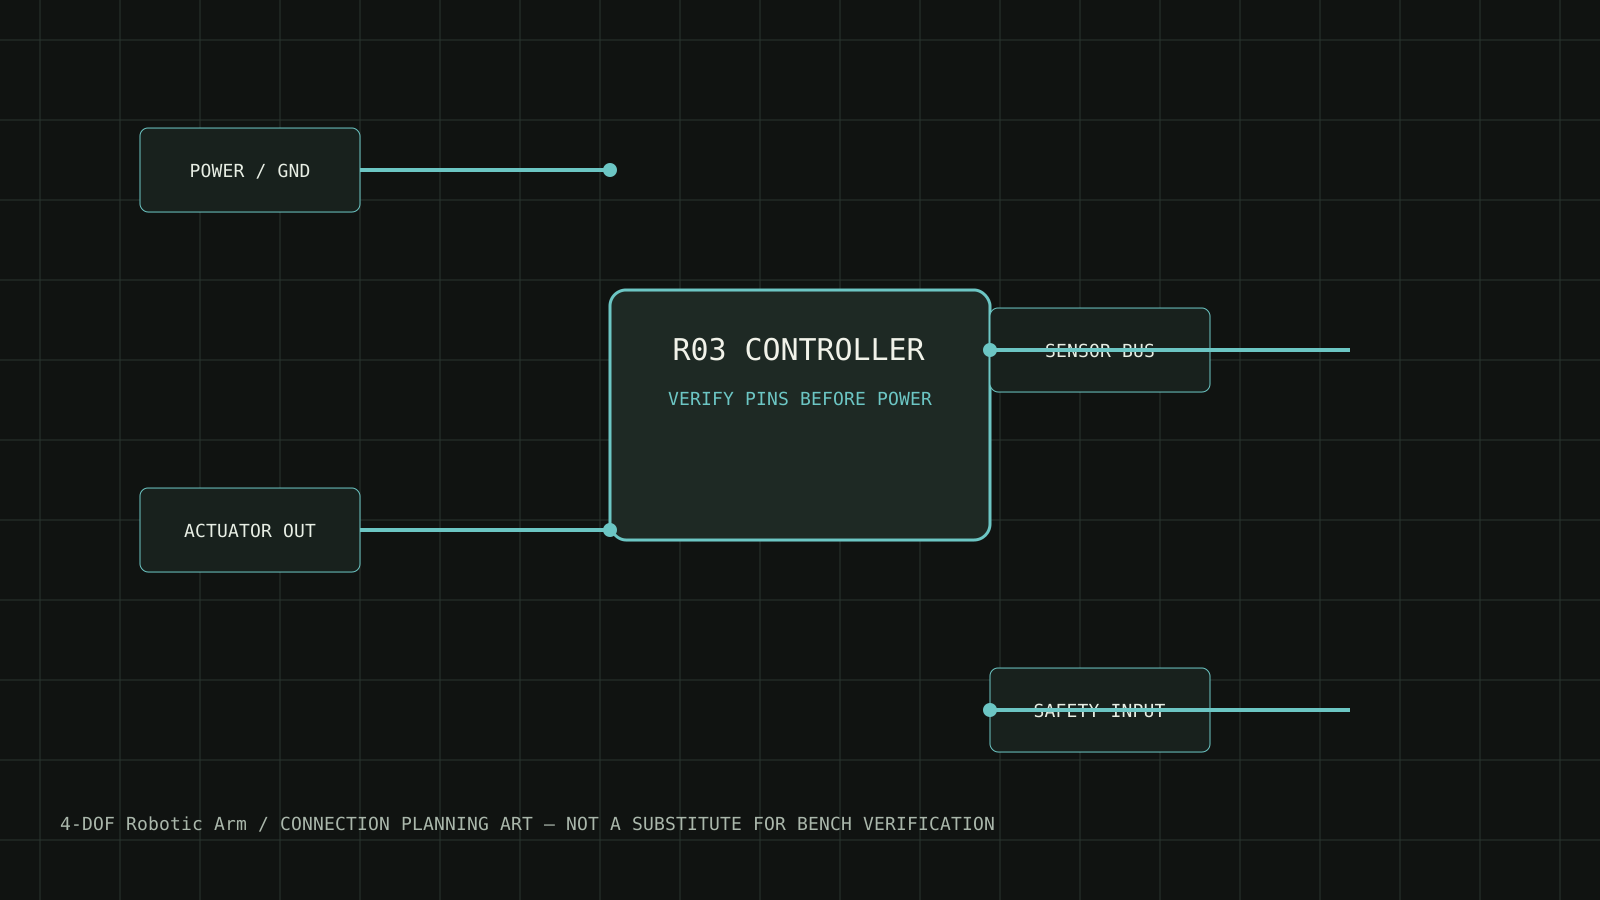
- Build and inspect the low-voltage wiring against the supplied connection diagram before connecting actuators.
- Flash the firmware, run the startup self-check, and record the printed board and firmware version.
- Calibrate the sensors and limits, then run the acceptance tests at the lowest safe energy level.
Test and expected result
Validate joint limits, pose repeatability over ten cycles, and unloaded-to-loaded behavior.
Safety and limits
Guard pinch points and validate unloaded before payloads.
Download connection diagram SVG