Advanced Robotics & Kinematics · Advanced
Differential Drive Mapping Robot
Encoder-equipped robot estimating pose while driving a marked route. Encoder-equipped robot estimating pose while driving a marked route.
Components
- MCU
- two motors
- encoders
- mapping/logging interface
Build steps
- Inventory the board, actuators, sensors, and power rails listed for R05.
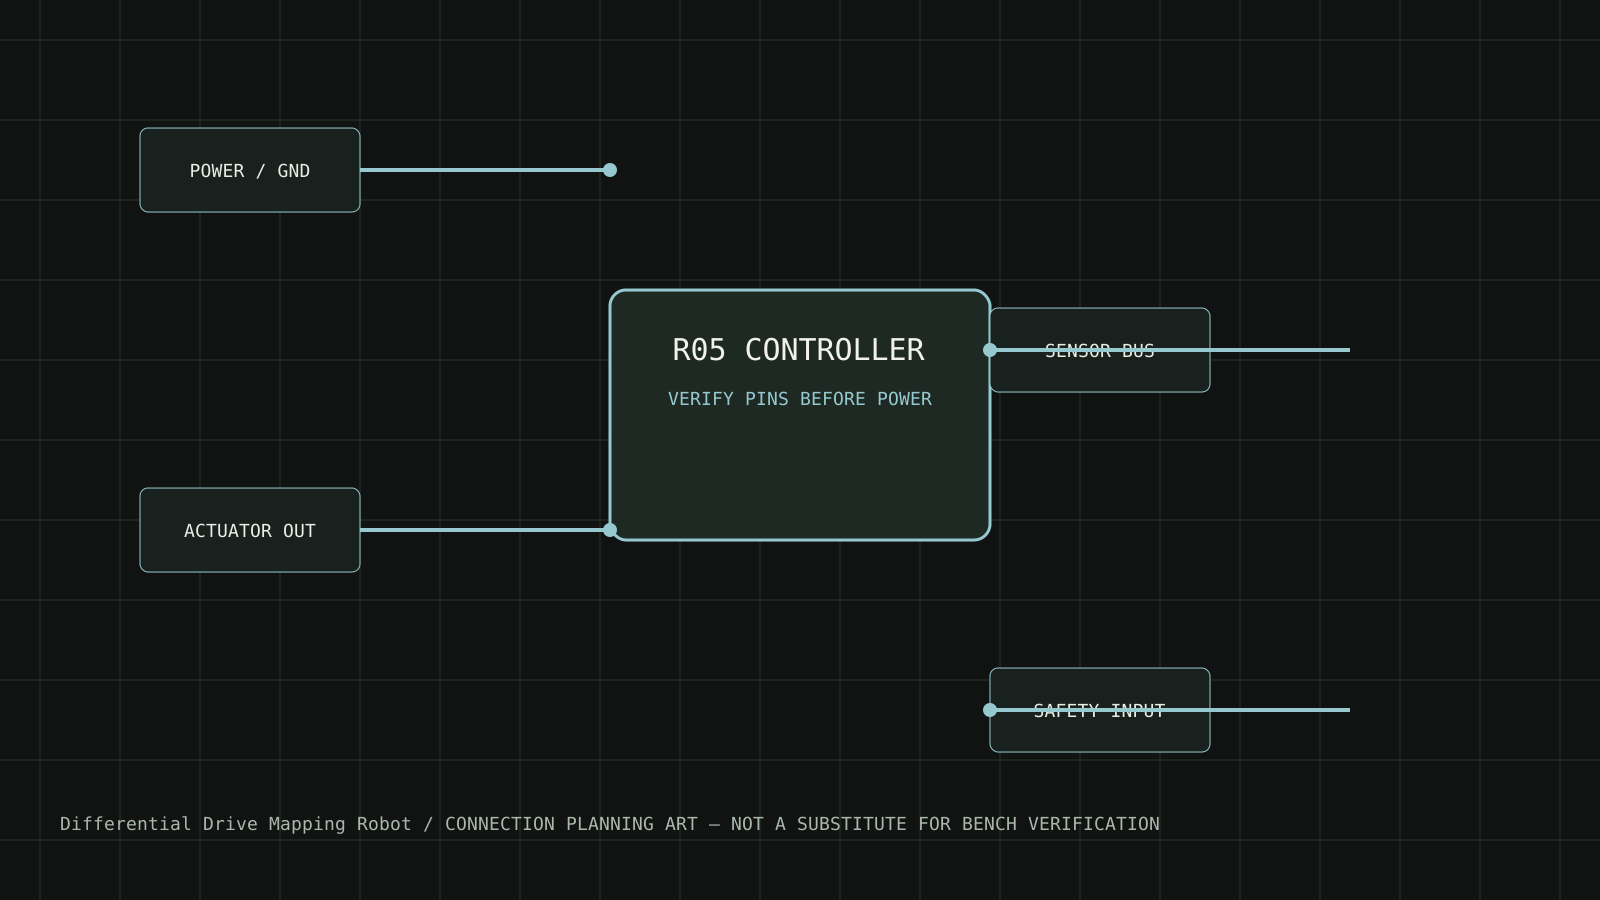
- Build and inspect the low-voltage wiring against the supplied connection diagram before connecting actuators.
- Flash the firmware, run the startup self-check, and record the printed board and firmware version.
- Calibrate the sensors and limits, then run the acceptance tests at the lowest safe energy level.
Test and expected result
Calibrate wheel diameter and axle spacing, then compare estimated versus measured final pose.
Safety and limits
Use a clear indoor course and a manual stop.
Download connection diagram SVG