Advanced Robotics & Kinematics · Advanced
Omnidirectional Inspection Base
Three- or four-wheel omni base translating and rotating independently. Three- or four-wheel omni base translating and rotating independently.
Components
- MCU
- omni motor drivers
- encoders
Build steps
- Inventory the board, actuators, sensors, and power rails listed for R06.
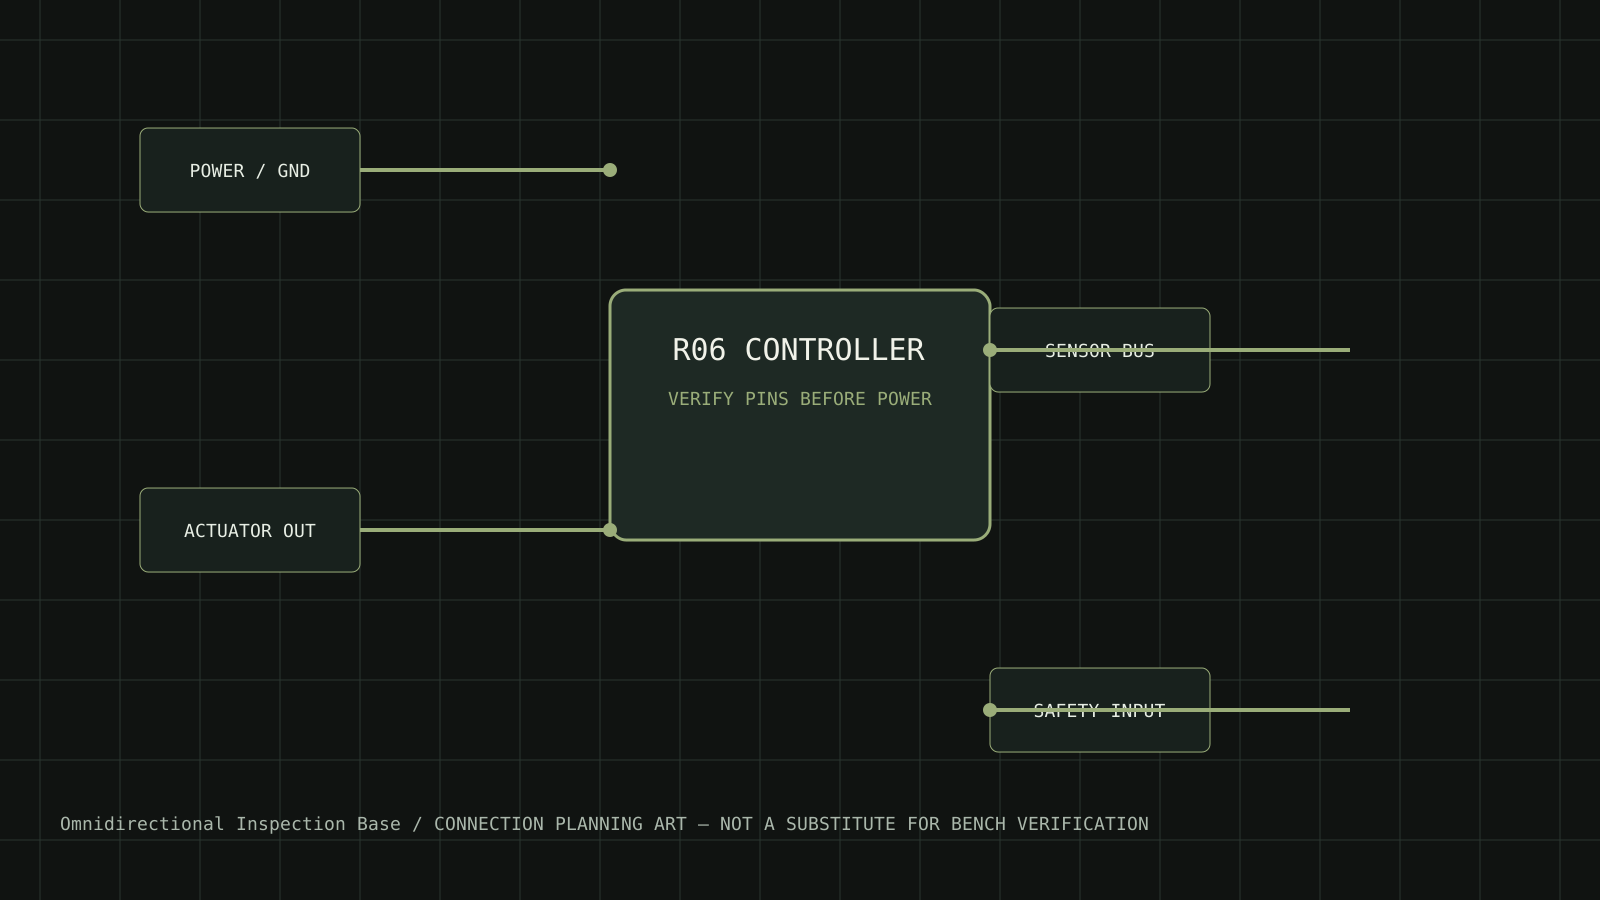
- Build and inspect the low-voltage wiring against the supplied connection diagram before connecting actuators.
- Flash the firmware, run the startup self-check, and record the printed board and firmware version.
- Calibrate the sensors and limits, then run the acceptance tests at the lowest safe energy level.
Test and expected result
Test commanded versus measured x, y, and yaw motion at low speed.
Safety and limits
Test each wheel independently before combined motion.
Download connection diagram SVG