Advanced Robotics & Kinematics · Advanced
Vision-Guided Pick-and-Place Arm
Camera-assisted arm moving known parts between two fixtures. Camera-assisted arm moving known parts between two fixtures.
Components
- MCU
- arm
- camera
- fixture coordinates
Build steps
- Inventory the board, actuators, sensors, and power rails listed for R07.
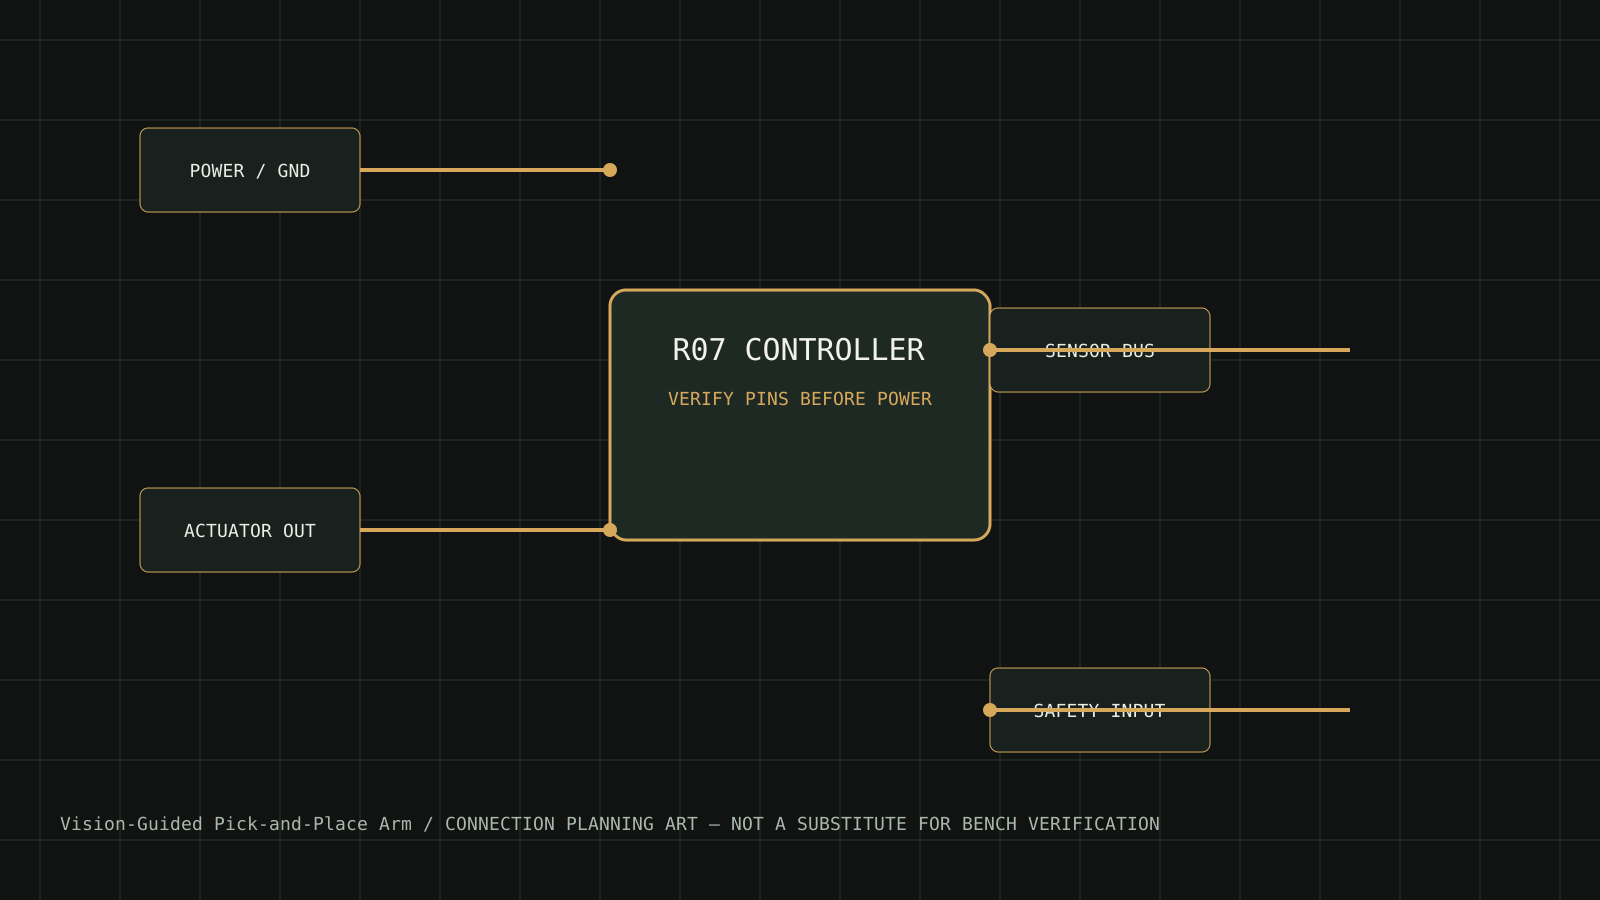
- Build and inspect the low-voltage wiring against the supplied connection diagram before connecting actuators.
- Flash the firmware, run the startup self-check, and record the printed board and firmware version.
- Calibrate the sensors and limits, then run the acceptance tests at the lowest safe energy level.
Test and expected result
Calibrate camera-to-arm transform, repeat ten pick cycles, and record missed picks.
Safety and limits
Use non-hazardous objects and a bounded pose library.
Download connection diagram SVG