Advanced Robotics & Kinematics · Advanced
Self-Leveling Stewart Platform
Six-actuator platform correcting tilt and translating a small payload. Six-actuator platform correcting tilt and translating a small payload.
Components
- MCU
- six actuators
- platform pose sensors
Build steps
- Inventory the board, actuators, sensors, and power rails listed for R10.
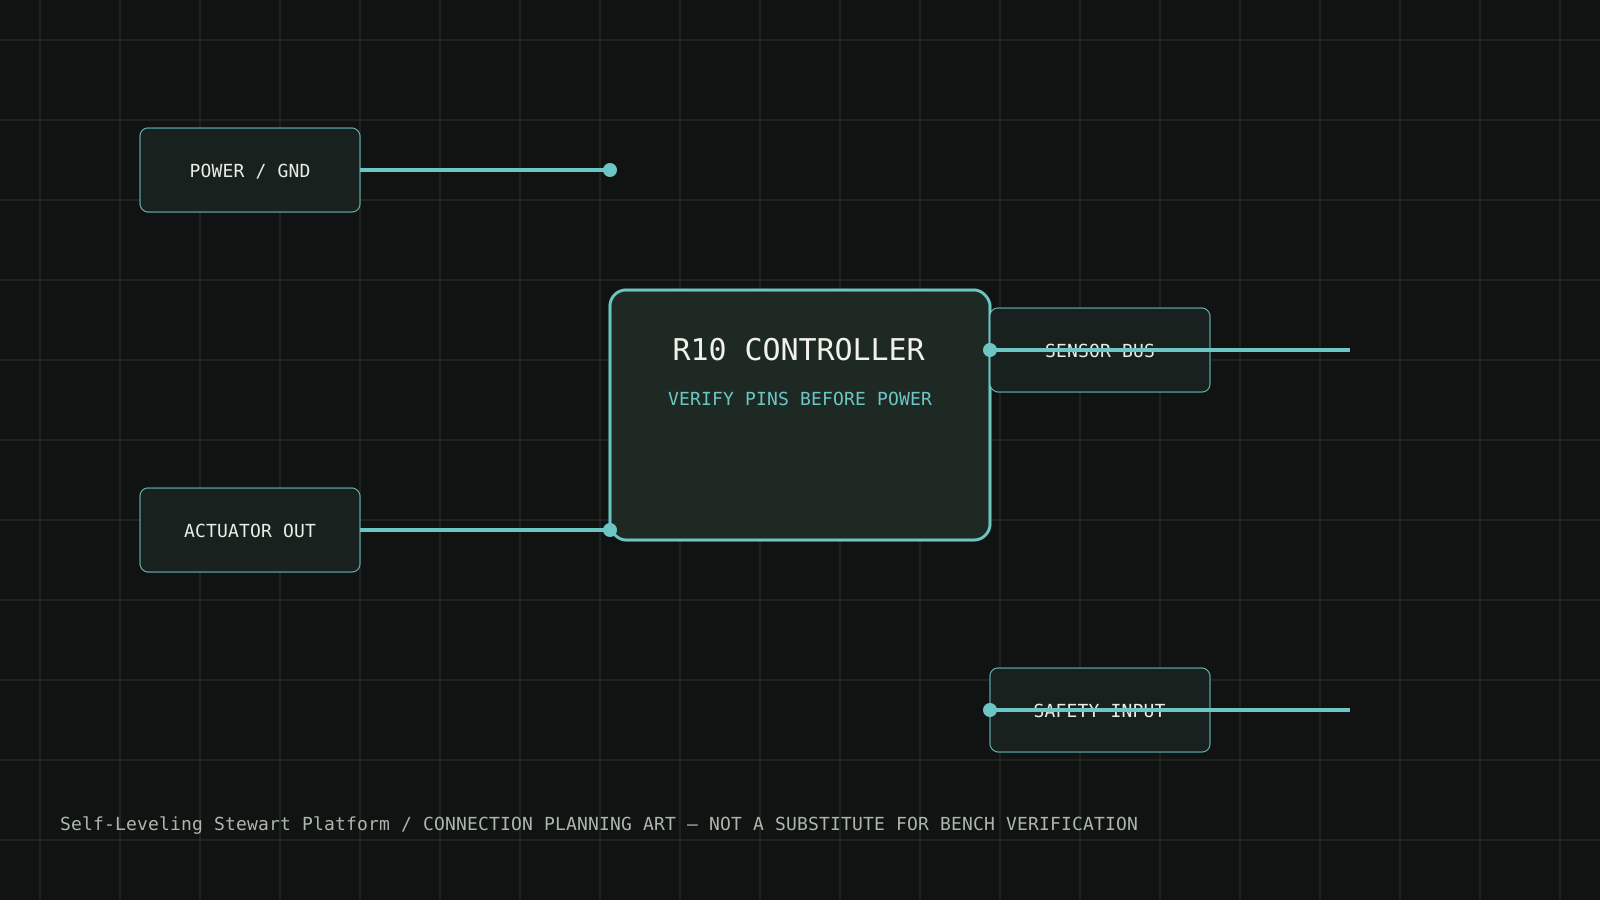
- Build and inspect the low-voltage wiring against the supplied connection diagram before connecting actuators.
- Flash the firmware, run the startup self-check, and record the printed board and firmware version.
- Calibrate the sensors and limits, then run the acceptance tests at the lowest safe energy level.
Test and expected result
Validate actuator homing, workspace limits, singularity avoidance, and pose error.
Safety and limits
Use a small payload and a mechanical catch.
Download connection diagram SVG